Replay of a real run
Loading run data…
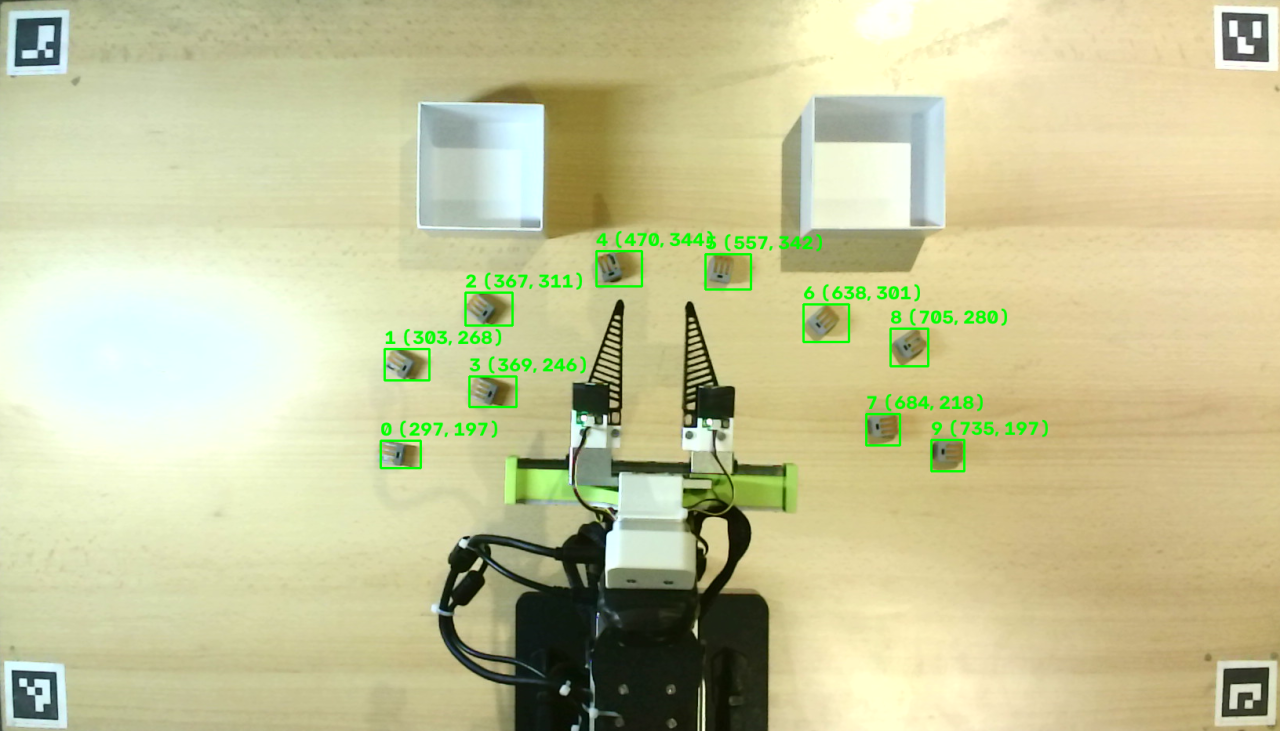
10 parts: 9 in the agent run plus 1 single pick just before it. Boxes checked by hand. The table image is the rescan taken before each pick.
An AI quality inspection cell for injection-molded parts.
Real hardware, no simulation.
Demo video: coming on 2 Nov
Loading run data…
10 parts: 9 in the agent run plus 1 single pick just before it. Boxes checked by hand. The table image is the rescan taken before each pick.
All numbers come from human-run tests, recorded in docs/DEVLOG.md.
| Run | What changed | Gripped on the first try | Sorted correctly | Time | Meta API cost |
|---|---|---|---|---|---|
| 30 Oct, run 1 | first 10-part run, close-up right after the lift | 10/10 | not checked: 5 parts on the left half read 0 levers (light), so they were sorted bad without a count | 7 min 20 s, about 44 s per part | 0.22 USD (about 2 cents per part, 14 Muse Spark calls) |
| 31 Oct, run 3 | lever direction from the slot axis, rescan after every part, fixed inspection station | 9/9 | 10/10 (9 in this agent run plus 1 single pick just before it; boxes checked by hand) | about 6.5 min, about 43 s per part | not measured (the credits page did not load) |
| 2 Nov, 10 parts, arm session | one session for all 10 parts (--plan-once --scan-at-station --arm-session), new empty-table image after turning the lamp away | 10/10 | 10/10 (7 good, 3 bad; 3 bad placed on purpose; boxes checked by hand, all correct) | 4 min 39 s first scan to report, about 28 s per part (24 to 28 s count to count) | not measured (5 Muse Spark calls) |
Run 2 (31 Oct, first run with the inspection station) gripped 10/10, but several parts were gripped along the wrong axis because the lamp shadow fooled the lever direction. That led to the slot axis fix used in run 3.
| Check | Result |
|---|---|
| Table camera calibration | RMS reprojection error 0.199 px (26 images) |
| Lever direction from the table camera (7 parts vs. photo) | 7/7 within about 10 deg with the slot axis (before: 3/7) |
| Control loop | 100 Hz, cycle period 10.09 ms mean, 10.20 ms max |
| Grip | touch contact on both fingers before the lift, every grip of run 3 on the first try |
| Offline test suite | 976 tests, no hardware, camera or network needed |
scan_table, inspect_and_sort(part_id), write_report or finish.| Meta tool | Where | What it does |
|---|---|---|
Muse Spark (muse-spark-1.3, Meta Model API) | muse_qc/agent/agent.py | The agent: reads the order, picks the next tool, reacts to failures and rescans, writes the summary |
SAM 3.1 (sam-3.1, Meta Model API) | muse_qc/vision/find_parts.py, muse_qc/vision/vision_sam.py | Confirms parts on the table image |
| SAM 3.1 | muse_qc/inspection/count_clips.py, muse_qc/inspection/count_retry.py | Finds the held part and counts its levers in the close-up |
| Muse Code (powered by Muse Spark) | the whole repository | Wrote all the code, logged task by task in docs/MUSE_CODE_LOG.md |
From run 3 on 31 Oct (docs/DEVLOG.md, output shortened):
agent -> scan_table()
tool: 8 parts found
grip yaw: lever 119.3 deg, offset -19.9 deg
inspect: levers 3 verdict good
tool: rescan found 7 parts
grip yaw: lever 102.3 deg, offset +9.9 deg
inspect: levers 2 verdict bad
...
tool: rescan found no parts, call scan_table
agent -> scan_table()
tool: no parts found
agent -> write_report()
agent finished: Sorted 9 parts: 6 good (3 levers), 3 bad (<3 levers), 0 failures/missed grips. Final rescan found no parts.
In short: every waypoint is checked before motion, every command is re-checked each control cycle, only a human starts hardware runs, speed is capped, tracking errors abort the move, touch sensing stops the descent, only grasp waypoints may go low, the model passes part IDs only, and devices are found by USB ID.
muse-qc-cell is a hackathon research prototype. Its safety layers are software checks only. They have not been assessed or certified by any testing body (for example TÜV), and the cell does not comply with the EU Machinery Regulation (EU) 2023/1230 or robot safety standards such as ISO 10218. There is no certified emergency stop, no guarding and no risk assessment. Do not use it in production or near people without a proper safety concept, risk assessment and certification.
I started this repository from scratch during the hackathon. Everything in muse_qc/, tests/, docs/ and calibration/ was written during the event.
Prior work, declared and not part of this submission: my Touch-Sensing Fin-Ray Gripper (hardware and firmware). I built it before the hackathon, and it is listed in the official Seeed reBot-DevArm repository under "DIY Soft Finger". New in this hackathon: muse_qc/gripper/gripper.py, which reads the gripper sensors over USB. See docs/THIRD_PARTY.md.